INDUSTRIAL AUTOMATION & SOFTWARE ENGINEERING
Intelligence for machines.
Motion for production.
Industrial automation and software solutions.

CONTROL. MOTION. INTEGRATION.
SOLUTIONS
Every system.
A considered solution.
We start where you need us.
We keep the whole system in mind.

01

02
Electrical & Panels
Electrical panels, machine commissioning, fault diagnosis and maintenance support.
PANELS · COMMISSIONING · MAINTENANCE

03
04
05
Motion Control
Positioning and coordinated motion control for servo axes.
SERVO · AXIS CONTROL · SYNC
06
Industrial Integration
Reliable data flow between machines, production lines and software.
EtherCAT · OPC UA · INDUSTRIAL NETWORKS
07
Cloud & Communications
Cloud and IP communications that connect your operations.
CLOUD · VoIP · IP PBX
ÇETİN / ENGINEERING EXPERIENCE
From the inside out.
The Engineering Behind Precision.
Every movement starts with a carefully designed control system. Inspect the servo motor from different angles.
Inside the Machine.
Housing, stator, rotor and encoder work together around one axis. Select a component to explore its role.
Precision Motion.
Assemble the motor, start its motion and adjust the visual speed. The percentage controls demonstration playback only.
Intelligent Control.
The PLC generates motion commands; EtherCAT carries data. The servo drive manages motor power, while encoder feedback returns to the control loop.
Real-World Automation.
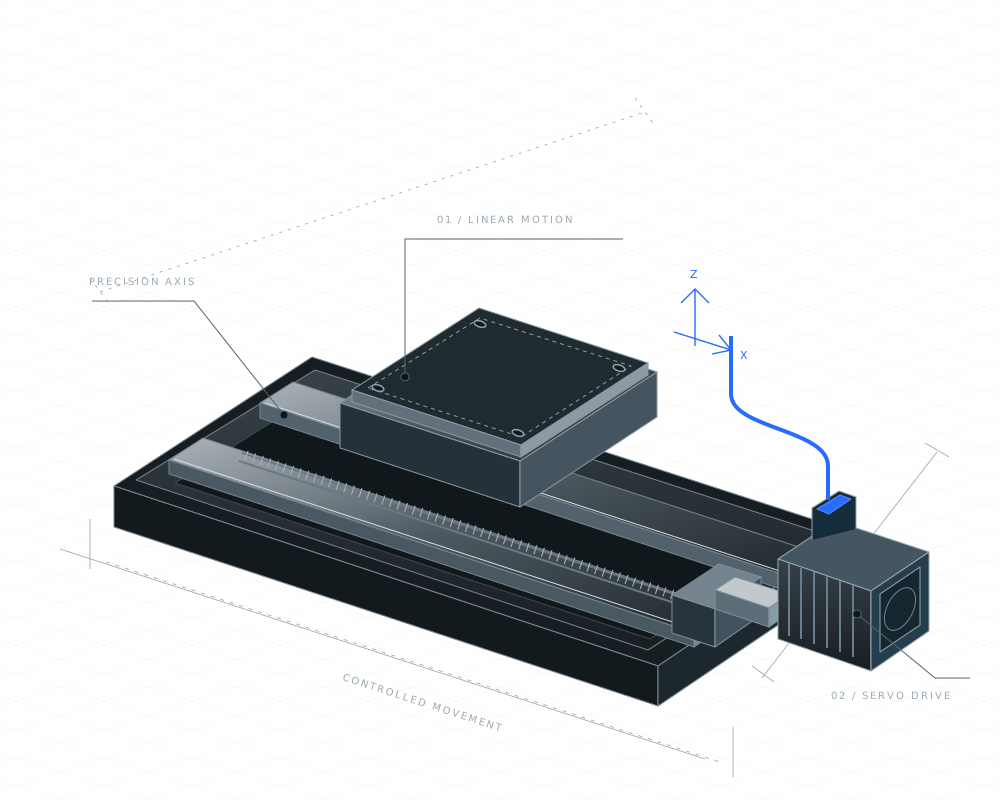
Rotary motion becomes positioning on a simplified linear axis. Controls, mechanics and software form one complete system.
Explore the technical details
Housing
The housing and front flange provide structural support and the mounting interface. They also help transfer heat to the surroundings.
A complete control path.
- PLCMotion command
- Command data
- EtherCATCommunication
- Cyclic data
- Servo DriveCurrent / torque control
- Motor power
- Servo MotorMechanical motion
EncoderPosition feedbackServo Drive
The drive closes its current / torque loops. Speed and position loops depend on the selected control architecture; feedback may also be shared with the PLC through EtherCAT.
Read the component descriptions
- Housing
- The housing and front flange provide structural support and the mounting interface. They also help transfer heat to the surroundings.
- Motor shaft
- The shaft rotates with the rotor and transmits torque to the machine through a coupling or mechanical transmission.
- Bearings
- Front and rear bearings support the shaft inside the housing and maintain rotor alignment across the air gap.
- Rotor
- The permanent-magnet rotor in this explanatory model interacts with the stator’s rotating magnetic field to produce torque.
- Stator
- The stationary laminated core and three-phase windings create a rotating magnetic field under controlled drive currents.
- Encoder
- The encoder reports shaft position. The drive uses this feedback for commutation and the configured motion control loops.
An original explanatory model created for Çetin Teknoloji. It is not an actual product CAD model, does not calculate real servo dynamics and is not connected to any machine.
PLC, drive and HMI: explore the control architecture
The centre of control.
The PLC evaluates inputs and machine states, then manages outputs and motion commands according to the control logic.
Select a component to explore the signal path. This is an educational model; it is not connected to a real machine.
ENGINEERING APPROACH
Understand the need.
Engineer the system.
We consider mechanics, electrical systems and software together.
From PLC control and commissioning to SCADA and custom software, we build understandable, maintainable systems.
Engineering design
Turning requirements into systems.
PLC control
The machine’s decision-making layer.
Motion control
The right position. The right moment.
Machine motion
Where code becomes physical.
Production data
From the shop floor to useful information.
Explore our process and technologies
01
Engineering design
Turning requirements into systems.
We consider the mechanical process, electrical architecture and software requirements together.
02
PLC control
The machine’s decision-making layer.
Sequences, state management and fault scenarios become readable, maintainable control software.
03
Motion control
The right position. The right moment.
Servo axes, motion profiles and synchronisation are designed around the mechanical process.
04
Machine motion
Where code becomes physical.
We validate control commands in the field and approach commissioning as a complete system.
05
Production data
From the shop floor to useful information.
Machine states and process data become accessible through operator interfaces and higher-level software.
Technology stack
Beckhoff
PC-based control
TwinCAT
Automation software
EtherCAT
Industrial communication
PLC
Deterministic control
SCADA
Supervision and monitoring
Software
Modern software engineering
Technology names describe our areas of work; they do not imply official partnership or certification.
CONTACT
Let’s build together.
Tell us what you need. Let’s define the scope together.
Zafer Çetin
Industrial automation & software engineering